Physics Models
This document describes the mathematical models and algorithms used in MVSim for simulating vehicle dynamics, wheel-ground interaction, and friction forces.
Overview
MVSim uses a modular, hierarchical physics architecture for efficient ground vehicle simulation:
Two-Level Physics Engine:
Upper Level - 2D rigid body dynamics using Box2D for chassis and blocks
Lower Level - Detailed wheel-ground interaction with realistic friction models
Core Components:
Wheel Dynamics - Individual wheel rotation and forces
Friction Models - Tire-ground interaction and slip
Vehicle Dynamics - Different locomotion systems (differential, Ackermann)
Controllers - Translating commands to torques
This hierarchical approach focuses on ground vehicles, allowing the use of a simplified 2D physics engine for body collisions while solving wheel-ground interaction forces separately, achieving high simulation efficiency without sacrificing realism.
Architecture Overview
Software Modules
MVSim consists of three main C++ modules with Python bindings:
mvsim-comms: Client-server communication framework
Publish-subscribe functionality via ZeroMQ sockets
Remote service invocation (RPC)
Portable, robust, and efficient data transport
mvsim-msgs: Message definitions
Interface Definition Language (IDL) using Google Protobuf
Compiled into C++ and Python libraries
Standardized data interchange format
mvsim-simulator: Core simulation engine
World file parsing and loading
Physics simulation (Box2D + custom wheel dynamics)
GUI for exploration and manipulation
GPU-accelerated sensor simulation
Integration Options:
Standalone:
mvsim-cliexecutable for launching and monitoring simulationsPython: Direct integration via
mvsim_commsandmvsim_msgspackagesROS 1/2: Node acting as bridge between MVSim and ROS ecosystem
Headless: Containerized execution for CI/CD pipelines
Physics Engine Selection
Box2D for Rigid Bodies:
MVSim uses the Box2D physics library [Cat05] for:
2D rigid body dynamics
Collision detection between vehicles and obstacles
Efficient constraint solving
Stable numerical integration
Why Box2D for Ground Vehicles:
Optimized for 2D scenarios (ground vehicle primary motion plane)
Lightweight and deterministic
No overhead from full 3D collision detection
Well-tested and stable in games and simulations
Custom Wheel Physics:
Box2D handles chassis dynamics, while MVSim implements custom:
Realistic tire friction models (Coulomb, Ward-Iagnemma, ellipse curves)
Wheel slip and rolling resistance
Torque distribution through differentials
PID velocity control with simulated odometry feedback
Sensor Simulation
GPU Acceleration:
MVSim achieves real-time sensor simulation through OpenGL GPU acceleration:
3D LiDAR: Millions of points per second
Depth Cameras: Real-time range image generation
RGB Cameras: Hardware-accelerated rendering of 3D scenes
Accurate Raytracing: All depth sensors measure distances to custom 3D models
Sensor Types:
Pin-hole RGB cameras
RGBD (depth) cameras
2D LiDAR scanners (with optional 3D raytracing)
3D LiDAR scanners (Velodyne, Ouster, Hesai models)
IMU (Inertial Measurement Unit)
GNSS/GPS receivers
Performance:
GPU acceleration enables:
Real-time simulation with multiple high-resolution sensors
Headless execution in Docker containers with GPU passthrough
Synthetic dataset generation for SLAM and perception research
1. Wheel Dynamics
Kinematics Model
Each wheel in MVSim is modeled as a rigid cylinder attached to a vehicle chassis. The velocity of a wheel center point is determined by rigid body kinematics.
Let \(\mathbf{v}_V\) be the velocity vector of the vehicle \(V\) reference point, and \(\boldsymbol{\omega}_V\) the vehicle angular velocity. The velocity vector of a wheel \(W\) center point, expressed in global coordinates \(O\), is given by:
where \(\times\) is the cross product and \({}^V\mathbf{t}_W\) is the translational part of the relative pose \({}^V\mathbf{T}_W\) of the wheel with respect to the vehicle reference frame.
For planar motion, this simplifies to:
where \((x_W, y_W)\) is the wheel position relative to the vehicle center, and \(\omega_V\) is the vehicle angular velocity around the vertical axis.
Wheel Local Coordinates
To evaluate tire-ground friction, velocities must be expressed in the wheel’s local frame, where the local x-axis points forward along the wheel’s rolling direction.
Let \(\theta\) be the rotation of the wheel with respect to the vehicle longitudinal axis. The velocity vector in the wheel frame \(W\) is:
where \(R_z(\theta)\) is the rotation matrix around the z-axis:
Properties
A wheel \(W\) is characterized by:
Location relative to chassis: \(L_w = \{x_w, y_w, \Phi\}\) [m, m, rad]
Diameter: \(d_w\) [m]
Width: \(w_w\) [m]
Mass: \(m_w\) [kg]
Moment of inertia: \(I_{yy}\) [kg·m²]
Spinning angular position: \(\phi_w\) [rad]
Spinning angular velocity: \(\omega_w\) [rad/s]
Thus, a wheel is represented as:
The moment of inertia for a cylinder is calculated as:
where \(R = d_w/2\) is the wheel radius.
Wheel Forces
Each wheel experiences the following forces:
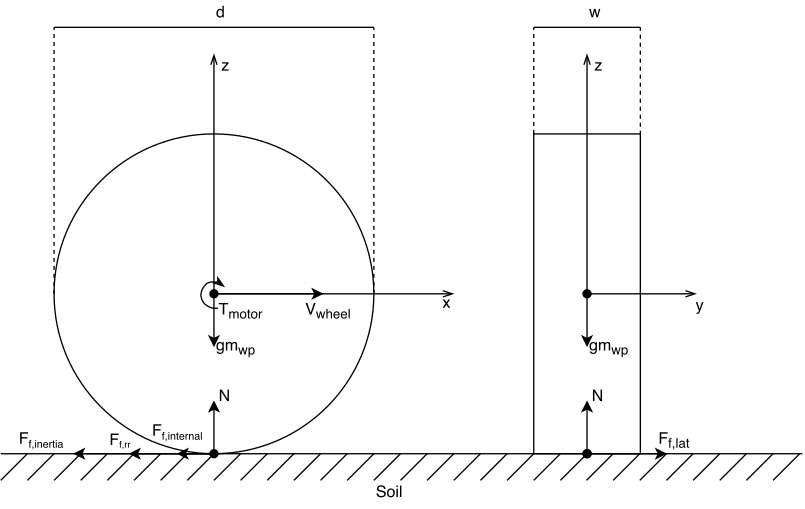
Forces acting on a wheel
Normal force \(F_z\) - Weight on the wheel from chassis [N]
Motor torque \(\tau\) - Applied by the motor [N·m]
Friction forces \(F_x, F_y\) - Ground reaction forces [N]
Velocity \(\vec{v} = (v_x, v_y)\) - Instantaneous velocity in local frame [m/s]
Wheel State Update
The wheel angular acceleration \(\alpha\) is computed from torque balance:
Closed-loop motor controllers (the PID ones) react to the wheel spin they measure, which
makes the wheel dynamics stiff: integrated explicitly, a wheel velocity loop becomes
unstable as soon as the wheel slips, unless \(K_P R \Delta t / I_{yy} < 2\). To avoid
that time step dependency, controllers also report a linear model of their torque around
the current spin speed (MotorTorqueModel):
where \(d\) (e.g. \(K_P R\) for a wheel velocity PID) is the motor damping. The
wheel spin is then integrated implicitly with respect to the motor torque, which amounts
to using an effective inertia \(I_{eff} = I_{yy} + \Delta t \cdot d\) with
\(\tau_{motor} = \tau_{unsat}\). If the motor would end the step saturated, the step
is solved again with the constant torque \(\pm\tau_{max}\) and \(I_{eff} = I_{yy}\)
(exact, since the torque law is monotonic). Controllers without feedback (raw,
twist_ideal) report \(d = 0\). The bearing damping \(C_{damp}\) and the slope of
the rolling resistance torque \(T_{rr}\) (see below) are integrated implicitly in the
same way, so \(I_{eff} = I_{yy} + \Delta t \, (d + C_{damp} + \partial T_{rr}/\partial \omega_w)\):
large damping values do not make the simulation unstable. This is implemented once, in
FrictionBase::solveWheelSpin(), and used by all friction models.
The angular velocity is then updated with:
And the angular position:
The angular position is wrapped to prevent numerical overflow:
2. Friction Models
Friction models determine the forces between wheels and ground based on wheel state, velocity, and applied torques.
Friction Model Base
All friction models implement the FrictionBase interface, which takes as input:
Friction Input Structure:
Normal force on wheel: \(F_z\) [N]
Motor torque: \(\tau_{motor}\) [N·m]
Wheel instantaneous velocity in local frame: \(\vec{v} = (v_x, v_y)\) [m/s]
Wheel properties: mass, diameter, inertia, current angular velocity
Simulation timestep: \(\Delta t\) [s]
Friction Output:
Friction force vector in vehicle frame: \(\vec{F}_{friction} = (F_x, F_y)\) [N]
Coordinate Frames
Each wheel has its own local coordinate frame:
X-axis - Points forward along wheel rolling direction
Y-axis - Points laterally (perpendicular to rolling direction)
Z-axis - Points upward (normal to ground)
Vehicle velocity must be transformed into each wheel’s frame:
where \(R(\Phi_w)\) is the rotation matrix for wheel yaw angle \(\Phi_w\).
Default Friction Model
The default friction model provides a simple but effective simulation of tire-ground interaction suitable for indoor robots and general applications.
XML Configuration:
<friction class="default">
    <mu>0.8</mu>              <!-- Friction coefficient -->
    <C_damping>1.0</C_damping>  <!-- Damping coefficient [N·m·s/rad] -->
    <C_rr>0.01</C_rr>          <!-- Rolling resistance coefficient -->
</friction>
Algorithm:
Transform vehicle velocity to wheel frame:
\[\vec{v}_w = (v_{wx}, v_{wy}) = R(-\Phi_w) \cdot \vec{v}_{vehicle}\]Calculate partial mass (portion of vehicle mass on this wheel plus wheel mass):
\[m_{wp} = \frac{F_z}{g} + m_w\]Compute maximum friction force:
\[F_{max} = \mu \cdot m_{wp} \cdot g\]Lateral friction (prevents side slip):
The impulse needed to eliminate lateral velocity:
\[F_{y,stick} = -\frac{v_{wy} \cdot m_{lat}}{\Delta t}\]where \(m_{lat}\) is the effective mass of the chassis at the wheel contact point along the wheel lateral direction \(\vec{n}\), \(m_{lat} = \left(1/M + (\vec{r} \times \vec{n})^2 / I_{zz}\right)^{-1}\), with \(\vec{r}\) the wheel position with respect to the center of mass (see Sequential Friction Impulses). If not provided, \(m_{wp}\) is used.
Longitudinal friction (rolling resistance and traction):
First, compute the desired wheel angular velocity for pure rolling (no slip):
\[\omega_{constraint} = \frac{v_{wx}}{R}\]The angular velocity impulse needed:
\[\Delta\omega_{desired} = \omega_{constraint} - \omega_w\]Angular acceleration to achieve this:
\[\alpha_{desired} = \frac{\Delta\omega_{desired}}{\Delta t}\]From torque balance, the friction force to roll without slipping is:
\[F_{x,stick} = k \cdot \frac{\tau_{motor} - I_{eff} \alpha_{desired} - C_{damp} \omega_w - T_{rr}}{R}, \quad k = \frac{1}{1 + I_{eff} / (m_{lon} R^2)}\]with \(I_{eff}\) the effective wheel inertia (see Wheel State Update), and \(m_{lon}\) the effective chassis mass at the contact point along the wheel longitudinal direction. The factor \(k\) accounts for the chassis reaction within the step, so the wheel rolls without slipping at the end of it (\(k=1\) for an infinitely heavy chassis).
Coulomb friction (friction circle): if the forces to stick fit in the friction circle, \(\| (F_{x,stick}, F_{y,stick}) \| \leq F_{max}\), they are used. Otherwise the wheel slides, and the friction force has magnitude \(F_{max}\) and opposes the slip velocity of the contact point, \((v_{wx} - \omega_w R, \; v_{wy})\). Its lateral component is limited to \(F_{y,stick}\), so it cannot reverse the lateral slip within the step, and the rest of the friction circle is left for \(F_x\). The wheel angular acceleration is then:
\[\alpha_{actual} = \frac{\tau_{motor} - R \cdot F_x - C_{damp} \omega_w - T_{rr}}{I_{eff}}\](Steps 5 and 6 are implemented in
FrictionBase::solveContact().) Since lateral and longitudinal forces share the same friction budget, a skid-steer robot (whose wheels must slide sideways to turn) turns slower than its wheel speeds imply: e.g. for wheels at \((\pm a, \pm b)\) and equal loads, spinning in place at \(\omega = \omega_{cmd} \, b^2 / (a^2 + b^2)\). This is a well-known behavior of real skid-steer robots, seewheel_separation_multiplierin Vehicles.Update wheel angular velocity:
\[\omega_w \leftarrow \omega_w + \alpha_{actual} \cdot \Delta t\]Transform friction force back to vehicle frame:
\[\vec{F}_{vehicle} = R(\Phi_w) \cdot (F_x, F_y)\]
Rolling Resistance Torque:
When C_rr > 0, a shaft-level torque opposing wheel spin is applied:
where \(F_{normal}\) is the normal force on the wheel, \(R\) is the wheel radius, and \(\omega_w\) is the wheel angular velocity. The \(\tanh\) provides a smooth transition near zero angular velocity, avoiding sign discontinuities. This torque is subtracted from the effective motor torque before computing longitudinal friction.
Parameters:
\(\mu\) - Coulomb friction coefficient (typical values: 0.7-0.9)
\(C_{damp}\) - Viscous damping in wheel bearing [N·m·s/rad]
\(C_{rr}\) - Rolling resistance coefficient (dimensionless, typical values: 0.005-0.03). Default: 0 (disabled)
Ward-Iagnemma Friction Model
An enhanced friction model that includes velocity-dependent rolling resistance, based on the paper by Ward and Iagnemma (2008) [WI08].
XML Configuration:
<friction class="wardiagnemma">
    <mu>0.7</mu>
    <C_damping>10</C_damping>
    <A_roll>50</A_roll>    <!-- Rolling resistance shape parameter -->
    <R1>0.0075</R1>        <!-- Static rolling resistance coefficient -->
    <R2>0.02</R2>          <!-- Dynamic rolling resistance coefficient -->
    <C_rr>0.0</C_rr>       <!-- Rolling resistance torque coefficient -->
</friction>
Rolling Resistance Model:
Rolling resistance is modeled as a combination of static and velocity-dependent forces. The model uses a continuously differentiable formulation:
where:
\(v_x\) - Longitudinal wheel velocity [m/s]
\(N\) - Normal force on wheel [N]
\(R_1\) - Static resistance coefficient (dimensionless)
\(R_2\) - Dynamic resistance coefficient [s/m]
\(A_{roll}\) - Shape parameter controlling transition from static to dynamic
Physical Interpretation:
At zero velocity: \(F_{rr} \approx 0\) (smooth, no singularity)
At low velocities: Static term \(R_1\) dominates
At high velocities: Dynamic term \(R_2 v_x\) dominates
The exponential provides smooth transition between regimes
Implementation:
The rolling resistance acts as an equivalent torque \(R \cdot F_{rr}\) opposing the wheel spin, so a free-rolling wheel transmits it to the chassis as a longitudinal force:
(Adding \(F_{rr}\) directly as a contact force would instead spin the wheel up, and the wheel would give that momentum back to the chassis in the next steps, cancelling most of the resistance.)
The lateral friction is calculated identically to the default model.
Parameter Selection:
Default values from the reference paper:
\(A_{roll} = 50\) - Provides smooth transition around 0.1 m/s
\(R_1 = 0.0075\) - About 0.75% of normal force
\(R_2 = 0.02\) - Velocity-dependent component
These can be tuned for different terrains (asphalt, dirt, sand, etc.).
Two Rolling Resistance Mechanisms:
This model supports two independent sources of rolling resistance that may be combined:
Ground-contact force (\(F_{rr}\)) from
R1,R2,A_roll— models terrain/ground contact drag (velocity-dependent, applied as an equivalent torque opposing the wheel spin).Tire deformation torque (\(T_{rr}\)) from
C_rr— models tire hysteresis as a shaft-level torque opposing wheel spin, using the same formula as the default friction model:\[T_{rr} = C_{rr} \cdot F_{normal} \cdot R \cdot \tanh(\omega_w \cdot 100)\]
Both may be enabled simultaneously for off-road scenarios where terrain drag and tire
hysteresis are distinct effects. For simpler configurations, use only one: either
R1/R2/A_roll or C_rr.
Ellipse Curve Friction Method
A physics-based tire model using elliptical friction curves that accounts for both slip angle and slip ratio, suitable for vehicle dynamics research and autonomous driving simulation.
XML Configuration:
<friction class="ellipse">
    <C_damping>0.05</C_damping>
    <C_rr>0.01</C_rr>          <!-- Rolling resistance coefficient -->

    <!-- Lateral slip parameters -->
    <C_alpha>8.5</C_alpha>
    <slip_angle_saturation>0.1</slip_angle_saturation>  <!-- rad -->
    <C_alpha_s>0.5</C_alpha_s>

    <!-- Longitudinal slip parameters -->
    <C_s>7.5</C_s>
    <slip_ratio_saturation>0.1</slip_ratio_saturation>
    <C_s_alpha>0.5</C_s_alpha>
</friction>
Slip Definitions:
Slip Angle \(\alpha\):
The angle between the wheel’s velocity direction and its heading direction. Since the velocity \((v_{wx}, v_{wy})\) is already expressed in the (possibly steered) wheel frame:
folded into \(|\alpha| \leq \pi/2\) for reverse motion.
Slip Ratio \(s\):
Measures the difference between wheel surface speed and ground speed:
where \(v_{wheel} = \omega_w \cdot R\) is the wheel surface speed. Clamped to [-1, 1].
Saturation Function:
Friction Force Equations:
The ellipse method computes maximum available forces based on the friction ellipse:
Longitudinal Force:
Lateral Force:
Both are magnitudes, used as the clamping bounds of the forces (the slip signs only determine the force directions through the impulse computation). Where:
\(F_z\) - Normal force [N]
\(C_s\) - Longitudinal stiffness coefficient
\(C_\alpha\) - Lateral stiffness coefficient
\(s_s\) - Slip ratio saturation value
\(\alpha_s\) - Slip angle saturation value
\(C_{s\alpha}, C_{\alpha s}\) - Coupling coefficients
Physical Interpretation:
The square root terms create an elliptical friction envelope: as one force component increases, the available force in the perpendicular direction decreases. This models the physical limitation that total tire force cannot exceed a maximum value.
Implementation Notes:
Compute slip angle and slip ratio from wheel kinematics
Calculate maximum available forces from ellipse equations
Compute desired forces to achieve target wheel velocities
Clamp desired forces to maximum available forces
Update wheel angular velocity based on actual applied forces
When C_rr is set, a rolling resistance torque \(T_{rr} = C_{rr} \cdot F_z \cdot R \cdot \tanh(\omega_w \cdot 100)\)
is subtracted from the effective motor torque, providing velocity-independent resistance
to wheel spin.
Gravity Slope Handling
All friction models receive per-wheel gravity slope forces via the gravSlopeForce
input field. When a vehicle drives on a terrain elevation map, the component of
gravitational force along the ground plane is computed for each wheel and passed to the
friction model.
The friction model incorporates these forces in both lateral and longitudinal directions:
Lateral: The gravity slope force is added to the impulse that cancels lateral velocity, preventing the vehicle from sliding sideways on slopes.
Longitudinal: The gravity slope force is added to the contact-patch friction (clamped by remaining friction capacity), counteracting the tendency to roll downhill.
This ensures vehicles remain stationary on slopes when no motor torque is applied, and behave realistically when driving on uneven terrain with elevation maps.
Per-Region Friction Overrides
MVSim supports spatially varying friction parameters using PropertyRegion world elements.
By defining regions with the property names friction_mu and/or friction_C_rr, you can
override the friction coefficient and rolling resistance on a per-wheel basis depending on
where each wheel contacts the ground.
During each simulation timestep, the world position of every wheel is queried against all
active PropertyRegion elements. If a wheel falls within a region that defines
friction_mu or friction_C_rr, the region’s value overrides the friction model’s
default parameter for that wheel only. Wheels outside any friction region use the values
from the vehicle’s <friction> XML configuration as usual.
This enables scenarios such as icy patches, sand zones, or other terrain variations without modifying vehicle definitions.
XML Example:
<!-- Ice patch: very low friction coefficient -->
<element class="property_region">
    <property_name>friction_mu</property_name>
    <value_double>0.15</value_double>
    <x_min>-7</x_min>  <y_min>-2</y_min>  <z_min>-1</z_min>
    <x_max>-3</x_max>  <y_max>2</y_max>   <z_max>2</z_max>
</element>

<!-- Sand zone: high rolling resistance -->
<element class="property_region">
    <property_name>friction_C_rr</property_name>
    <value_double>0.08</value_double>
    <x_min>3</x_min>  <y_min>-2</y_min>  <z_min>-1</z_min>
    <x_max>7</x_max>  <y_max>2</y_max>   <z_max>2</z_max>
</element>
Supported properties:
friction_mu(double) — Overrides the Coulomb friction coefficient \(\mu\). Applies to the Default and Ward-Iagnemma friction models. The Ellipse Curve method scales its slip-based curves so their peak equals it.friction_C_rr(double) — Overrides the rolling resistance coefficient \(C_{rr}\). Applies to all three friction models.
3. Vehicle Dynamics Models
Vehicle dynamics models define how wheels are arranged and controlled to produce vehicle motion.
Vehicle Base Class
The VehicleBase class provides common functionality:
Weight Distribution: Computes the normal force \(N_i\) on each wheel at \((x_i, y_i)\) (vehicle frame) from the force and moment balance of the rigid vehicle (no pitch nor roll motion): center of mass \((x_c, y_c)\) (from the chassis shape and wheels, as in Box2D) at height \(h\) (from the chassis
zmin/zmaxand the wheel radii), gravity \((g_x, g_y, g_z)\) in the vehicle frame (slopes), and the (low-pass filtered) chassis acceleration \((a_x, a_y)\) for the load transfer when accelerating, braking or turning:\[\sum N_i = M g_z, \quad \sum N_i x_i = M \left(g_z x_c - h (a_x - g_x)\right), \quad \sum N_i y_i = M \left(g_z y_c - h (a_y - g_y)\right)\]With more than 3 wheels this is statically indeterminate: the minimum-norm solution is used, removing wheels that would need negative loads (the vehicle would tip over them). Vehicles that cannot stand on their wheels alone (e.g. a semi-trailer) also rest on their joint anchors (the load on the anchor is not passed to the other body). Each wheel also gets the share of the gravity force along the ground plane proportional to its load.
VehicleBase::getWheelLoads()returns the loads. With suspension, this balance (with no acceleration) gives the static loads, and the springs and dampers add the load transfer.Wheel Velocity Computation: Calculates each wheel’s velocity from vehicle twist
For a wheel at position \((x_w, y_w)\):
\[\vec{v}_w = \vec{v}_{chassis} + \vec{\omega}_{chassis} \times \vec{r}_w\]In 2D:
\[v_{w,x} = v_x - \omega \cdot y_w\]\[v_{w,y} = v_y + \omega \cdot x_w\]Force Application: Applies wheel friction forces to vehicle body through Box2D
Sequential Friction Impulses
Friction forces are computed as the impulses that cancel the slip of each wheel within one time step. Computing them for all wheels from the same chassis velocity (a Jacobi iteration) over-corrects the yaw rate when the wheels are far from the center of mass compared to the yaw radius of gyration (e.g. long vehicles), ending up in a limit cycle (a jittering vehicle that never comes to rest). Instead, the wheels are solved one after another (sequential impulses, i.e. a Gauss-Seidel iteration): the chassis velocity used for each wheel includes the impulses of the previous ones,
and each wheel uses the effective chassis mass at its contact point. Several sweeps over all wheels are done on each time step (before solving a wheel again, its previous impulse is removed from the chassis velocity estimate and its spin speed restored), so the wheels and the chassis reach a consistent solution, also for stiff wheel controllers on light robots. The wheel order is reversed on every step to avoid a left/right bias. Ideal controllers skip this, since friction forces are not applied to the chassis.
Chassis Suspension
Optionally (see vehicles), the chassis (the sprung mass \(m_s\), the chassis mass without the wheels) moves with respect to the body that carries the wheels, whose pose is still the one of the 2D dynamics and the terrain. The chassis has three degrees of freedom relative to it, measured from the static equilibrium: heave \(z\) (up), roll \(\phi\) (left side up) and pitch \(\theta\) (nose down), \(\delta = (z, \phi, \theta)\). It rotates about a pivot point on the ground, under its center of mass, which is at height \(h\). Each wheel \(i\), at \((x_i, y_i)\) relative to the pivot, has a spring \(k_i\) and a damper \(c_i\), whose deflection (up) is:
The equations of motion are:
with the inertias about the pivot, the destabilizing effect of gravity on a chassis whose center of mass is above the pivot (the second term of \(K\)), and the inertial forces of the chassis in the (accelerating) vehicle frame. So, the chassis dives when braking, squats when accelerating, and rolls outwards in turns. \((a_x, a_y)\) is the vehicle acceleration in its frame (limited to \(2g\): larger values are spikes, e.g. from collisions or the velocity steps of ideal controllers).
Ground excitation. The wheels’ body moves with the terrain (e.g. over bumps): let \(\dot{q}_b\) be its velocity along its normal and its roll and pitch rates (finite differences of its pose between steps). The springs and dampers act on the relative motion, while the inertia acts on the absolute one, so with the absolute chassis velocity \(w = \dot{\delta} + \dot{q}_b\) as state:
Exact integration. This is a linear time-invariant system, \(\dot{x} = A x + B u\), with \(x = (\delta, w)\) and \(u = (\dot{q}_b, F)\):
For inputs constant during a time step \(\Delta t\), its exact solution is \(x_{k+1} = \Phi x_k + \Gamma u_k\), with \(\exp\left(\begin{bmatrix} A & B \\ 0 & 0 \end{bmatrix} \Delta t\right) = \begin{bmatrix} \Phi & \Gamma \\ 0 & I \end{bmatrix}\), computed once for each time step value. Hence, it is stable for any time step, and the frequencies and damping of the chassis motion do not depend on it.
Vibration modes. The undamped modes are the solutions of
\(K v = \omega^2 M v\): natural frequency \(f_j = \omega_j / 2\pi\), damping
ratio \(\zeta_j = v_j^T C v_j / (2 \omega_j v_j^T M v_j)\) (exact for damping
proportional to stiffness), and shape \(v_j\) (heave and pitch are coupled if the
center of mass is not centered between the axles). They are logged when the vehicle is
loaded, e.g.: Suspension modes: roll 0.96 Hz (zeta=0.24), pitch 1.24 Hz (zeta=0.28),
heave 1.40 Hz (zeta=0.30). The chassis is unstable if a frequency is not positive (the
springs are too soft for the height of its center of mass), which is reported as an
error. Rotations without stiffness (e.g. the pitch of a vehicle whose wheels all lie on
one axle) are locked.
Spring sizing. By default, each corner gets the spring and damper that give the heave natural frequency \(f\) and damping ratio \(\zeta\) to its share of the static load, \(m_i = N_i / g\):
so the heave frequency is \(f\) regardless of the weight distribution. The roll and pitch frequencies follow from the geometry.
Effect of the damping ratio. The videos below compare the same vehicle over a 10 cm speed bump with worn dampers (\(\zeta = 0.1\), left) and firm ones (\(\zeta = 0.6\), right), with the same springs. With little damping, the chassis keeps oscillating at its natural frequencies for seconds after the bump; with firm dampers, it settles almost at once, at the cost of harder jolts (larger peak vertical accelerations). The plots are the readings of an IMU on the chassis, and the insets the images of a camera on it, which move with the chassis as in a real vehicle.
Steady state. For constant accelerations, \(K \delta = F\), e.g. braking at \(a_x\) and turning at \(a_y\) (with the diagonal terms of \(K\), e.g. \(K_{\theta\theta} = \sum k_i x_i^2 - m_s g h\), if the center of mass is centered between the corners):
Effects.
Wheel loads: \(N_i = N_i^0 - k_i s_i - c_i \dot{s}_i\) (not negative), with \(N_i^0\) the static loads. In steady state, they equal the quasi-static load transfer of the chassis; in transients, they include the bounce of the chassis.
Sensors and visual models are mounted on the chassis: their pose is
Simulable::getChassisPose(), the vehicle pose composed with the chassis pose relative to it (a rotation about the pivot plus the heave). The wheels do not move.IMU: its angular velocity includes the chassis roll and pitch rates (absolute, so also those of the terrain), and its acceleration the one of the chassis at the sensor point, \((z_s \dot{w}_\theta, \; -z_s \dot{w}_\phi, \; \dot{w}_z + y_s \dot{w}_\phi - x_s \dot{w}_\theta)\), and the gravity seen from the tilted chassis.
The vehicle pose (e.g. the
base_linkframe in ROS) is still the one of the wheels’ body, so the relative pose of sensors is constant, as in a real vehicle: the chassis motion appears in their data.
Limitations. Linear model of small angles, with no suspension travel limits nor tire vertical stiffness (wheel hop); no suspension geometry (roll centers, anti-dive): the pivot is on the ground; the load of a semi-trailer on its kingpin is not passed to the suspension of the tractor, and vehicles that cannot stand on their wheels alone (e.g. semi-trailers) do not support it.
Differential Drive Dynamics
Two independently driven wheels that control translation and rotation through differential wheel speeds.
Variants:
differential- Two wheels (basic configuration)differential_3_wheels- Three wheels (two driven + one caster). The caster swivels freely: on every step, it is aligned with the velocity of its contact point.differential_4_wheels- Four wheels (two driven pairs)
Kinematics:
Vehicle motion is determined by wheel angular velocities \(\omega_l, \omega_r\):
Angular Velocity:
where \(y_l, y_r\) are lateral positions of left and right wheels.
Linear Velocity:
Note
The current implementation assumes no lateral slip (\(v_y = 0\)). This is an approximation valid for low-speed indoor robots. Future versions may include lateral dynamics.
Inverse Kinematics (for control):
Given desired \(v_{desired}, \omega_{desired}\), compute wheel velocities:
where \(w = |y_r - y_l|\) is the wheel track width, times the optional
wheel_separation_multiplier of the twist_pid controller (default 1), which
compensates the slower turning of skid-steer robots (see the friction models).
Ackermann Steering Dynamics
Four-wheeled vehicle with front-wheel steering. Rear wheels provide traction while front wheels steer.
Wheel Configuration:
Rear wheels: Fixed orientation, independently or jointly driven
Front wheels: Steered wheels with Ackermann geometry
Steering Geometry:
To prevent wheel slip during turns, inner and outer wheels must have different
steering angles. The equivalent steering angle \(\delta\) follows the one commanded by
the controller at a maximum rate max_steer_rate_deg (0, the default, means
instantaneous steering). Given \(\delta\):
where:
\(w\) - Track width (distance between front wheels)
\(l\) - Wheelbase (distance between front and rear axles)
Inner/outer determined by turn direction
Geometric Derivation:
For a turn with radius \(R\) measured to the rear axle center:
The inner wheel turns around radius \(R_{inner} = R - w/2\) and outer wheel around \(R_{outer} = R + w/2\), leading to the above steering angles.
Odometry Estimation:
Similar to differential drive but using rear wheel velocities:
Ackermann with Drivetrain
Extended Ackermann model with realistic powertrain including differentials that distribute torque from a single “engine” to multiple wheels.
Differential Types:
Open Differential:
Simple torque splitting according to preset ratios:
where \(K_f\) is front/rear split and \(K_{fL}, K_{rL}\) are left/right splits.
Torsen Limited-Slip Differential:
Self-locking differential that distributes more torque to the wheel with better traction, based on the Torsen (torque-sensing) design [Cho88].
It locks both outputs together until the ratio of their torques reaches the bias ratio \(B\) (e.g. \(B=2\) lets one output get up to twice the torque of the other), and then they slip. With an input torque \(\tau_{in}\) and split \(K_s\), the outputs are:
where the locking stiffness \(k = I/\Delta t\) (\(I\) the inertia of each output)
removes the speed difference within one step, i.e. the outputs stay locked. The locking
torque is integrated implicitly together with the wheel spin (it is part of the wheel
MotorTorqueModel). With no input torque there is no locking, as in a real Torsen.
Physical Meaning:
While both outputs have traction: they turn together (locked), and the torque goes to where it is needed, up to the bias ratio.
When one wheel slips (e.g. on ice): the other one gets up to \(B\) times its torque, instead of the same torque as with an open differential.
4WD Configuration:
For all-wheel drive:
Center differential splits torque between front and rear (with Torsen if configured)
Front differential distributes to left/right front wheels
Rear differential distributes to left/right rear wheels
Each differential can be independently configured as open or Torsen type.
4. Motor Controllers
Controllers translate high-level motion commands into wheel torques.
Controller Types
Raw Controllers:
Direct specification of wheel torques and steering angles. No feedback control.
PID Controllers:
Closed-loop control using Proportional-Integral-Derivative feedback to track velocity setpoints.
Ideal Controllers:
Perfect tracking (kinematic control). Instantly achieves desired velocities without dynamics. The wheel friction forces are still evaluated (for wheel spin and logging), but not applied to the chassis.
Differential Twist PID Controller
Controls linear velocity \(v\) and angular velocity \(\omega\) using PID regulators on each wheel.
Control Law:
Compute desired wheel velocities from twist command:
\[v_l^{des} = v - \frac{\omega w}{2}, \quad v_r^{des} = v + \frac{\omega w}{2}\]Compute actual wheel velocities from odometry (i.e. from the wheels spin):
\[v_l^{act} = \omega_l R_l, \quad v_r^{act} = \omega_r R_r\]PID control for each wheel:
\[e_i = v_i^{des} - v_i^{act}\]\[\tau_i = K_P e_i + K_I \int e_i \, dt + K_D \frac{de_i}{dt}\]Apply torque limits:
\[\tau_i = \text{clamp}(\tau_i, -\tau_{max}, \tau_{max})\]With
<enable_antiwindup>true</enable_antiwindup>, the integral term is corrected by back-calculation while the output is saturated.Zero setpoint (stopping): the integral term is dropped and only the proportional action brakes the wheels, \(\tau_i = \text{clamp}(-K_P v_i^{act})\). It always opposes the current motion and vanishes at zero speed, so the vehicle neither coasts nor rebounds.
Tuning Guidelines:
\(K_P\) - Proportional gain: Higher values → faster response, may cause oscillation
\(K_I\) - Integral gain: Eliminates steady-state error, may cause overshoot
\(K_D\) - Derivative gain: Damping, rarely needed for velocity control
\(\tau_{max}\) - Keep it below the traction limit of the driven wheels, \(\mu \, m_{wheel} \, g \, R\), so the controller cannot spin them (skid-steer vehicles are the exception: turning in place requires the wheels to slip)
The mvsim-pid-tuner tool proposes gains automatically.
Ackermann Twist Controller
Controls forward velocity and steering angle to achieve desired twist.
Control Strategy:
Compute turn radius from twist command:
\[R = \frac{v}{\omega}\]Compute steering angle:
\[\delta = \arctan\left(\frac{l}{R}\right)\]where \(l\) is the wheelbase.
Apply Ackermann geometry to get individual wheel angles
Rotate desired velocity vector by steering angle
Use PID to control each front (driven) wheel speed, accounting for different radii in turns. The actual speed of each wheel is measured from its own spin (as a motor encoder would), so the loop also limits the slip of the driven wheels.
The ackermann_drivetrain twist controller is similar, but it controls the
driveshaft speed (the mean longitudinal speed of the driven axles) with a single PID,
whose torque is then split among the wheels by the differentials.
Special Cases:
\(\omega \approx 0\): Straight line, \(\delta = 0\)
Small \(R\): Limit \(\delta\) to \(\delta_{max}\)
Ackermann Steering Controller
Direct control of steering angle and forward speed (alternative to twist control).
Inputs:
Desired steering angle \(\delta_{des}\)
Desired forward velocity \(v_{des}\)
Implementation:
Uses the twist controller internally after converting steering + speed to equivalent twist command.
5. Integration and Timestep
Hierarchical Physics Simulation
MVSim employs a two-level hierarchical approach for efficient physics simulation:
Upper Level (2D Rigid Bodies):
Vehicles and obstacles (“blocks”) are modeled as 2D rigid bodies using Box2D
For vehicles with custom 3D meshes, equivalent 2D collision polygons are computed
Box2D provides collision detection and integrates forces/torques on rigid bodies
Uses fixed timestep numerical integration
Lower Level (Wheel-Ground Interaction):
Detailed wheel dynamics and friction forces computed separately
Applied before and after each Box2D physics step
Accounts for realistic tire-ground interaction
Simulation Loop
The main simulation loop executes Algorithms 1 and 2 for each timestep \(\Delta t\).
Algorithm 1: Pre-Timestep Processing
for all vehicles v:
    # Evaluate chassis weight W on each wheel:
    W[] ← v.weight_on_wheels()

    # Evaluate motor torques T (includes kinematics and PID control):
    T[] ← v.invoke_motor_controllers()

    for all wheels w[i] in v:
        # Compute wheel center point velocity vector (Eq. 1):
        v_w ← v_g + (-ω * w.y, ω * w.x)

        # Transform to wheel local coordinates:
        v_local ← rotate_z(v_w, θ_i)

        # Evaluate friction model (see Section 2):
        {F_x, F_y} ← v.friction_model(v_local, T[i], W[i])

        # Apply force to vehicle chassis at wheel center:
        v.apply_force({F_x, F_y}, t_W)
Key Points:
weight_on_wheels(): Distributes chassis weight among wheelsinvoke_motor_controllers(): Handles vehicle kinematics (Ackermann vs. differential) and PID control to achieve velocity setpoints using simulated odometryWheel slippage affects odometry, realistically replicating real-world behavior
Forces are applied to chassis via Box2D at wheel contact points
Box2D Physics Step:
After Algorithm 1, Box2D integrates rigid body dynamics:
Updates positions and velocities of all rigid bodies
Handles collisions between vehicles and obstacles
Applies computed wheel friction forces
Algorithm 2: Post-Timestep Processing
for all vehicles v:
    # Process all sensors (depth cameras, LiDAR, etc.):
    for all sensors s in v:
        s.process()

    # Integrate wheel spinning angles:
    for all wheels w in v:
        w.phi ← wrap_to_pi(w.phi + w.omega * dt)
Key Points:
Sensor simulation uses GPU-accelerated OpenGL pipeline
Wheel angles are wrapped to prevent numerical overflow
Ground-truth pose/velocity updated from Box2D state
Terrain Elevation Support
MVSim supports vehicles with 3 or more wheels moving on terrain elevation maps:
Determine elevation of each wheel-ground contact point
Apply quaternion Horn method [Hor87] to solve for optimal vehicle attitude
This allows vehicles to tilt, pitch, and roll on uneven terrain while maintaining contact with the ground
Note: Despite using a 2D physics engine, MVSim uses SE(3) poses (full 3D position and orientation) rather than SE(2), enabling certain degrees of freedom for vertical movement and attitude changes when traversing elevation models.
Timestep Selection
Fixed timestep (recommended): Set
<simul_timestep>in world fileAdaptive timestep: Set to 0 for automatic determination
Recommended values:
Indoor robots: 10-20 ms (50-100 Hz)
Outdoor vehicles: 5-10 ms (100-200 Hz)
High-speed dynamics: 1-5 ms (200-1000 Hz)
Stability Considerations
The explicit Euler integration used for wheel dynamics is conditionally stable:
where \(\omega_n\) is the natural frequency of the wheel-ground system.
For most applications, timesteps of 10 ms or less ensure stability.
6. Coordinate Systems and Transformations
MVSim uses SE(3) poses (Special Euclidean group in 3D) to represent vehicle positions and orientations, even though the underlying physics engine operates in 2D. This enables vehicles to traverse elevation maps with realistic pitch and roll.
Coordinate Frames
World Frame (O):
Fixed inertial reference frame with origin at the simulation world origin.
Vehicle Frame (V):
Moving frame attached to vehicle chassis reference point (may or may not coincide with center of mass), aligned with vehicle heading.
Wheel Frame (W):
Rotating frame attached to each wheel, with x-axis along rolling direction, y-axis along the wheel axle, and z-axis pointing upward.
Homogeneous Transformations
Vehicle pose with respect to world origin is represented as a 4×4 homogeneous transformation matrix:
where:
\({}^O\mathbf{R}_V\) is a 3×3 rotation matrix (vehicle orientation in world frame)
\({}^O\mathbf{t}_V\) is a 3×1 translation vector (vehicle position in world frame)
Similarly, wheel pose relative to vehicle:
Transformation Compositions
Wheel Pose in World Frame:
Velocity Transformations:
For a point rigidly attached to the vehicle, its velocity in the world frame is:
where \(\times\) denotes the cross product.
Planar Simplifications:
For planar motion (z = 0, no pitch/roll), rotations reduce to:
And the cross product simplifies to:
Inverse Transformations:
To transform from vehicle to wheel coordinates:
For rotation matrices: \(\mathbf{R}^{-1} = \mathbf{R}^T\)
SE(3) vs SE(2) Usage
Why SE(3) for Ground Vehicles:
Despite using a 2D physics engine, MVSim employs SE(3) (6-DOF) poses instead of SE(2) (3-DOF) for several reasons:
Terrain Following: Vehicles can pitch and roll on elevation maps
Realistic Attitude: Captures vehicle tilt during turns or on slopes
Sensor Simulation: 3D LiDAR and cameras require full 3D pose
Multi-Wheel Contact: Horn quaternion method determines optimal 3D attitude from wheel ground contact points
Constrained Motion:
While pose is SE(3), motion is primarily constrained to:
Translation: Primarily in x-y plane (z from terrain elevation)
Rotation: Primarily yaw, with pitch/roll from terrain geometry